Glossary · Robotics and Physical AI
Hands, Grippers and End Effectors
68 terms in the Robotics and Physical AI glossary, each with its one-line definition.
68 terms, A to Z
- Adaptive Gripper Gripper whose fingers passively conform to an object's shape so one tool can handle many different parts.
- Allegro Hand Four-fingered, 16-joint torque-controlled robot hand from Wonik Robotics that is a long-standing research platform for dexterous manipulation.
- Angular Gripper Gripper whose jaws pivot open and closed around a hinge like pliers, allowing wide opening and side approach.
- Anthropomorphic Hand Robot hand shaped and moving like a human hand, usually with five fingers and an opposable thumb, so it can use human tools.
- Arc Welding Torch Welding robot tool that feeds wire and shielding gas and carries the arc that melts and joins metal.
- Bellows Suction Cup Suction cup with accordion folds that compress to seal on parts at varying heights or on curved surfaces.
- Bernoulli Gripper Gripper that blows air across its face so low pressure lifts thin flat parts such as wafers without touching them.
- Bimanual Manipulation Performing tasks with two arms or hands working together, such as holding a part with one while fastening with the other.
- Bin Picking Using a 3D camera and grasp planning to pick randomly jumbled parts one at a time out of a container.
- Collision Sensor Breakaway device between wrist and tool that yields and signals a stop when the tool hits something, then resets.
- Compliance Device Passive wrist unit that lets the tool shift or tilt slightly so it can absorb small position errors during insertion.
- Contact-Rich Manipulation Robot tasks such as insertion, wiping or assembly that depend on careful, sustained physical contact with objects.
- Deformable Object Manipulation Robot handling of objects that bend or change shape, such as cloth, cables, food and bags.
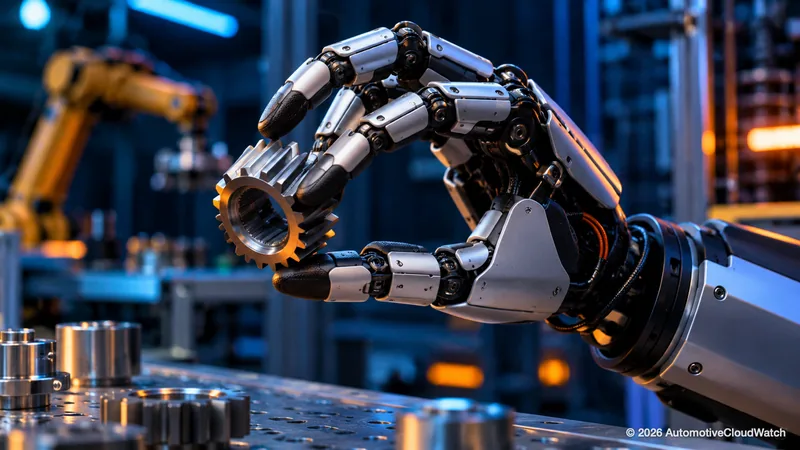 Dexterous Hand Multi-jointed robot hand that can grasp many objects and reposition them in the hand without putting them down.
- Dress Pack Bundle of cables, hoses and protective sleeves running along a robot arm to feed power, air and signals to its tool.
- Electric Gripper Motor-driven gripper whose opening, speed and grip force can be programmed and that reports whether a part is held.
- Electroadhesive Gripper Gripper that holds fabric, paper and light items with static electricity from electrodes in a flexible pad.
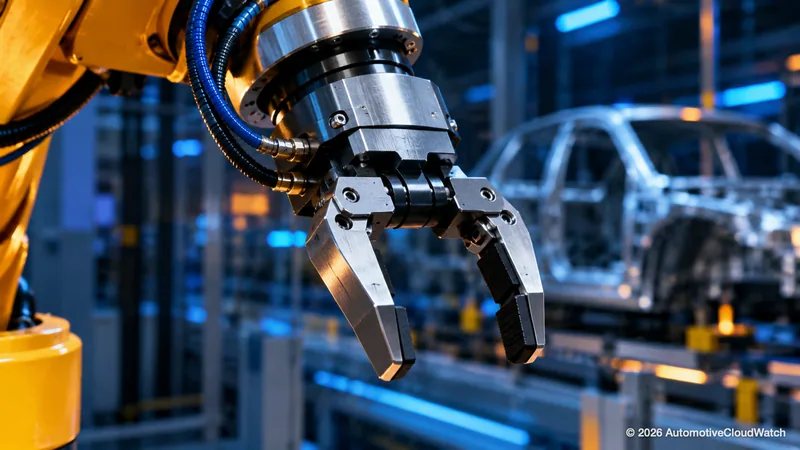 End Effector The device at the end of a robot arm that does the actual work, such as a gripper, welding gun or suction cup.
- End-of-Arm Tooling EOAT Industry term for everything mounted at a robot's wrist, including grippers, cups, sensors, changers and dress packs.
- Fin Ray Gripper Flexible triangular finger inspired by fish fins that bends toward an object and wraps around it when pressed.
- Fixture Device that holds a part firmly in a known, repeatable position so a robot or machine can work on it.
- Foam Vacuum Gripper Suction gripper with a foam pad over many holes so it can grip irregular, porous or partly covered surfaces.
- Force Closure Grasp that uses contact forces and friction to resist any push or twist on the held object.
- Form Closure Grasp or fixture that locks an object in place purely through the shape and placement of contacts, without friction.
- Granular Jamming Gripper Grain-filled soft bag that flows around an object, then turns rigid under vacuum to lock it in place.
- Grasp Force The squeezing force a gripper applies, high enough to stop slipping yet low enough not to crush or mark the part.
- Grasp Quality Metric Score rating how securely a candidate grasp resists disturbances, used by planners to choose among grasps.
- Grasp Taxonomy Catalog that sorts the ways hands hold objects into families such as power and precision grasps.
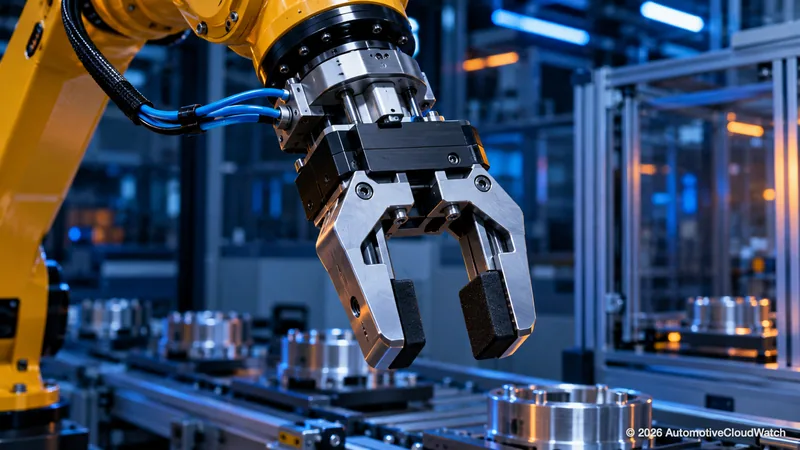 Gripper Robot tool that picks up and holds objects by squeezing, suction, magnetism or enclosing them.
- Gripper Fingers Custom fingers or jaw inserts bolted to a gripper and shaped for the specific part being handled.
- Gripper Stroke Total distance a gripper's jaws travel from fully open to fully closed, setting the range of part sizes it handles.
- Hand Degrees of Freedom Number of independent motions a robot hand can make, from one for a simple gripper to about 20 for advanced hands.
- Haptic Feedback Touch and force sensations delivered to a person, such as a teleoperation controller pushing back when the robot makes contact.
- In-Hand Manipulation Turning or repositioning an object within the hand without setting it down, such as spinning a pen.
- Inspire Hand Low-cost six-actuator dexterous robot hand from Beijing Inspire Robots, widely fitted to research humanoids.
- ISO 11593 International standard defining vocabulary and characteristic presentation for automatic robot tool changers.
- ISO 14539 International standard setting vocabulary and specification presentation for grasp-type robot grippers.
- ISO 9409-1 International standard fixing the bolt pattern and dimensions of the mounting flange at the end of a robot arm.
- LEAP Hand Low-cost open-source 16-joint dexterous hand from Carnegie Mellon University built from servos and 3D-printed parts.
- Linkage-Driven Hand Robot hand whose fingers are moved by rigid bars and levers from palm motors rather than by cables.
- Machine Tending Using a robot to load raw parts into a machine such as a CNC or press and unload finished ones.
- Magnetic Gripper Gripper that holds iron and steel parts with magnets, often switchable permanent magnets that hold through power loss.
- Manual Tool Changer Quick-release coupling that lets an operator swap a robot's tool by hand in seconds without tools.
- Needle Gripper Gripper that pushes small angled needles into soft porous materials like textiles or carbon mats to lift them.
- Nonprehensile Manipulation Moving objects without grasping them, by pushing, sliding, tilting, flipping or tossing.
- Opposable Thumb Thumb able to rotate to face the fingers, enabling pinches and precise fingertip grips in robot hands.
- Parallel Gripper Gripper whose two or three jaws slide straight toward each other with fingertips kept parallel.
- Peg-in-Hole Classic robot assembly task of inserting a round part into a tightly fitting hole, used to benchmark force control.
- Pick and Place Basic robot job of picking an object up in one place and putting it down in another.
- Piece Picking Picking individual items from totes or shelves to fill orders, the most labor-intensive step in e-commerce warehouses.
- Pneumatic Gripper Gripper driven by compressed air pistons that is fast, strong and cheap, and the most widely installed factory type.
- Power Grasp Grip in which fingers and palm wrap around an object for strength, like holding a hammer handle.
- Precision Grasp Grip that holds an object between fingertips and thumb for fine control, such as pinching a pin.
- Regrasping Changing how a robot holds an object by setting it down and picking it up again, or by passing it between hands.
- Remote Center Compliance RCC Passive wrist device that pivots a part about a point near its tip so insertion errors correct themselves.
- Rotary Bell Atomizer Paint robot spray tool whose fast-spinning cup flings paint into a fine, electrostatically charged mist.
- Screwdriving End Effector Robot tool that drives screws automatically with a feeder and records torque and angle for each screw.
- Shadow Dexterous Hand Human-sized, tendon-driven research hand with about 20 actuated joints from London's Shadow Robot Company.
- Soft Gripper Gripper with soft flexible fingers, often air-inflated silicone, that molds around delicate or irregular items like food.
- Spot Welding Gun Robot tool that clamps steel sheets between copper electrodes and passes high current to fuse a weld spot.
- Suction Cup Flexible cup that seals against a surface so vacuum can hold the object, the building block of vacuum grippers.
- Three-Finger Gripper Gripper with three fingers, either centric jaws for round parts or adaptive fingers that wrap irregular shapes.
- Tool Changer Coupling that lets a robot swap tools automatically while passing air, power and signals through the joint.
- Tool Flange Standardized round mounting plate at the end of a robot's last joint where tools are bolted on.
- Underactuation Having fewer motors than movable joints, so some joints move passively through linkages, tendons or springs.
- Vacuum Generator Device that creates vacuum for suction grippers, either a compressed-air venturi ejector or an electric pump.
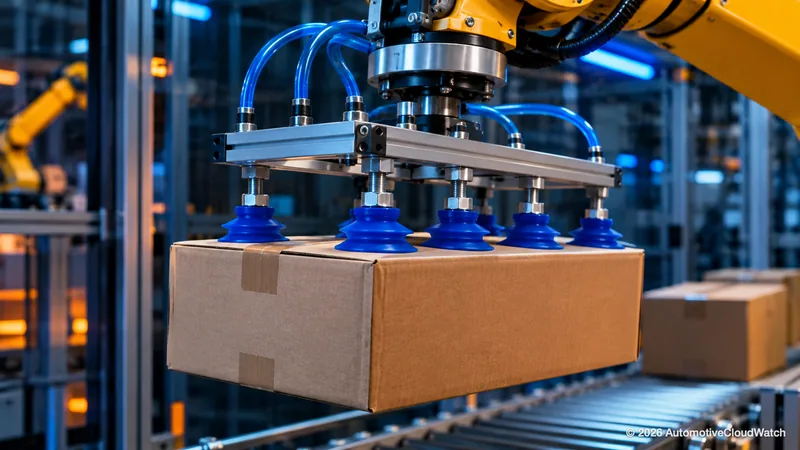 Vacuum Gripper Gripper that holds objects with suction cups connected to a vacuum source, dominant in box handling and palletizing.
- Vacuum Switch Small pressure sensor on a suction gripper that confirms a part is held and flags failed picks.
Full entry for members
Every term has a full entry for members: the plain-words definition, the practitioner note and the typed links between terms.
ACW Robotics and Physical AI Glossary, edition 2026.11.1. The headword and one line are open to everyone.