Glossary · Robotics and Physical AI
Safety, Standards and Deployment
148 terms in the Robotics and Physical AI glossary, each with its one-line definition.
148 terms, A to Z
- 80 W Rule Japanese safety rule that once required fencing for industrial robots with motors above 80 watts, relaxed in 2013 to allow cobots
- AI Robot Association AIRoA Japanese association building shared datasets and a data platform for training robot foundation models, supported by NEDO
- ANSI/A3 R15.06 Main US safety standard for industrial robots and robot cells, adopting ISO 10218 and adding a US part for robot users
- ANSI/A3 R15.08 US standard series for the safety of industrial mobile robots such as AMRs, with parts for makers, integrators and users
- ANSI/ITSDF B56.5 North American safety standard for driverless and guided industrial vehicles such as AGVs and automated forklifts
- Association for Advancing Automation A3 North American robotics and automation trade group that writes US robot safety standards and publishes robot order statistics
- Bill of Materials BOM Complete list of a product's parts and their costs, the main way the industry estimates what a humanoid costs to build
- Biomechanical Limits Maximum force and pressure a robot may apply to each human body region on contact, set to stay below the onset of pain
- Brake Test Automatic routine check that pushes each robot joint against its holding brake to confirm the brake can still hold the arm
- Brownfield Deployment Installing robots into an existing site built for people rather than a new purpose built facility
- CE Marking EU label showing a product meets European safety, health and environmental rules, required before robots or cells can be sold there
- Collaborative Application Complete robot setup, including tool, parts and task, designed and verified so people can safely work close to it
- Collaborative Operation Older standards term for running a robot while a person shares its workspace during production, now called collaborative application
- Collaborative Workspace Area inside a robot cell where a robot and a person can be present at the same time while the robot works
- Commissioning Installing, setting up, testing and starting a robot system at the customer site until it runs production
- Common Cause Failure CCF Single event or shared flaw that disables two redundant safety channels at once, defeating the redundancy
- Cycle Time Time a robot or cell takes to finish one job and be ready for the next, the basic measure of automation speed
- Diagnostic Coverage DC Share of dangerous failures in a safety system that its own self checks can detect
- Domestic Substitution Chinese push to replace imported robot components and machines with Chinese made ones
- Duty Cycle Share of time a motor or robot works under load versus resting, which governs heat buildup and ratings
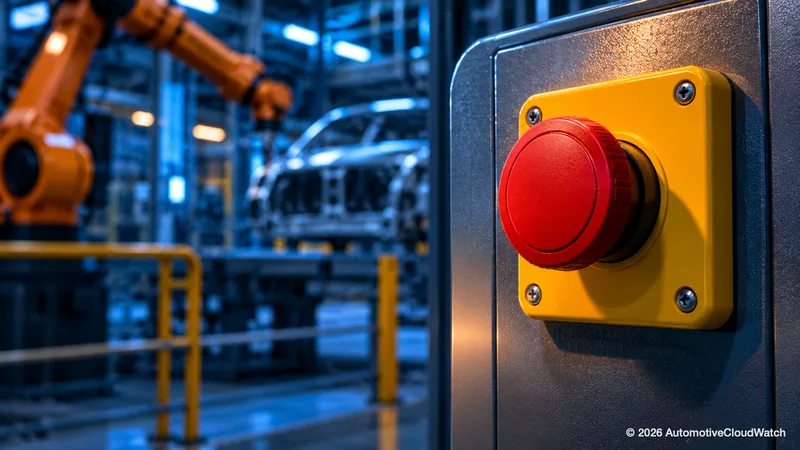 Emergency Stop e-stop Big red button anyone can hit to bring a machine to an immediate safe stop, overriding all other functions
- Enabling Device Three position grip switch on a teach pendant that must be held in the middle for the robot to move during manual operation
- EU AI Act EU law regulating AI by risk level, treating AI used as a safety component of machinery, including robots, as high risk
- EU Machinery Regulation EU law setting safety requirements for machinery including robots, replacing the Machinery Directive from January 2027
- Factory Acceptance Test FAT Test of a robot system at the builder's facility before shipment, where the customer checks it works as promised
- Fail Safe over EtherCAT FSoE Protocol that carries emergency stop and other safety signals over the same EtherCAT network as normal control data
- Fenceless Robot Robot setup that works without a physical fence, protecting nearby people with sensors and safety software instead
- Fully Loaded Labor Cost Full cost of employing a worker, including benefits, taxes, training and turnover, used to judge whether a robot pays off
- Functional Safety Part of machine safety that relies on control systems responding correctly to faults, engineered to defined reliability targets
- GB 11291 Chinese national safety standard for industrial robots and robot systems, adopted from ISO 10218
- GB/T 12643 Chinese national robotics vocabulary standard, aligned with ISO 8373
- Goods-to-Person GTP Warehouse picking method where machines bring items to a worker at a fixed station instead of the worker walking the aisles
- Hand Guiding Moving a robot by pushing it by hand through a handle with a safety switch while it runs slowly under safety monitoring
- High-Speed Manual Mode T2 Manual robot mode allowing a program to run at full speed under an enabling switch, tightly restricted and absent on many robots
- Human-Robot Collaboration HRC Work where people and robots share a workspace and tasks at the same time, the main use case for cobots
- Human-Robot Interaction HRI Study and design of how people and robots communicate and work together, including speech, gestures, trust and safety
- Humanoid Robot Guiding Opinions 2023 MIIT policy setting Chinese national humanoid goals for key components by 2025 and mass production by 2027
- IEC 60204-1 International standard for the electrical equipment of machines, defining stop categories 0, 1 and 2
- IEC 61496 International standard for electro sensitive protective equipment such as light curtains, safety scanners and safety cameras
- IEC 61508 Foundational international functional safety standard for electrical, electronic and programmable safety systems
- IEC 61800-5-2 International standard defining drive safety functions such as safe torque off and safely limited speed
- IEC 62061 International standard for safety control systems on machinery, rated by SIL and derived from IEC 61508
- IEC 62443 International standard family for cybersecurity of industrial automation and control systems, now relevant to robot safety
- Industrial Robot Special Education Mandatory Japanese safety training for anyone who teaches, inspects or repairs industrial robots within their range of motion
- Ingress Protection Rating IP rating Two digit code rating how well a device is sealed against dust and water, such as IP67
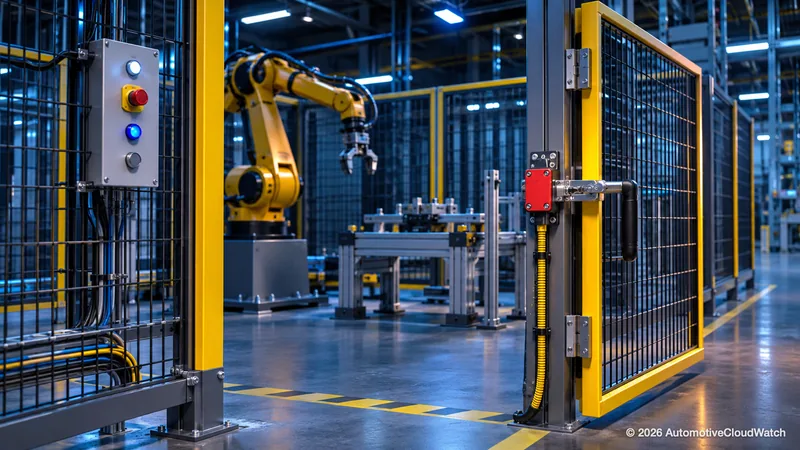 Interlocked Guard Robot cell door with a safety switch that stops the robot when opened and needs a deliberate reset to restart
- International Federation of Robotics IFR Global robotics industry association known for its yearly World Robotics report on robot installations
- International Robot Exhibition iREX Major robot trade show held in Tokyo every two years where makers launch new industrial and service robots
- ISO 10218-1 International safety standard for the design and construction of industrial robots, Part 1 of ISO 10218
- ISO 10218-2 International safety standard for industrial robot applications and cells, now home of collaborative safety requirements
- ISO 12100 Basic international machinery safety standard setting the general method for identifying hazards and reducing risk
- ISO 13482 International safety standard for personal care robots such as mobility aids, exoskeletons and person carriers
- ISO 13849-1 Widely used standard for designing safety related machine control parts, grading each safety function by performance level
- ISO 13850 International standard for the design of emergency stop devices and the emergency stop function
- ISO 13855 International standard for calculating how far a safety sensor must sit from a hazard based on human approach speed
- ISO 14119 International standard for choosing and fitting interlocking devices on machine guards and preventing their defeat
- ISO 25785-1 Draft safety standard for industrial robots that must actively balance, such as humanoids and legged robots
- ISO 3691-4 International safety standard for driverless industrial vehicles including AGVs and autonomous mobile robots
- ISO 8373 International robotics vocabulary standard defining robot, industrial robot, service robot and related terms
- ISO/TS 15066 Technical specification that gave the first detailed cobot safety guidance, including body region force and pressure limits
- Japan Robot Association JARA Japan's robot makers association, which publishes official robot production and order statistics
- Japan Robot Strategy Japanese national robotics plan launched in 2015 as the New Robot Strategy to make Japan a leading robot innovation hub
- JIS B 0134 Japanese Industrial Standard for robotics vocabulary, the counterpart of ISO 8373
- JIS B 8433 Japanese Industrial Standard for industrial robot safety, the counterpart of ISO 10218
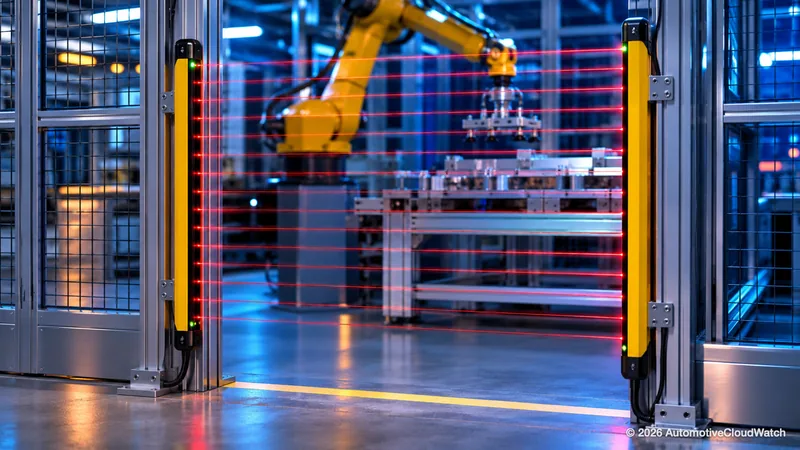 Light Curtain Safety device that projects a row of infrared beams across an opening and stops the machine if a beam is broken
- Lights-Out Manufacturing Production that runs fully automatically with no people on site, a long standing automation ideal
- Lockout/Tagout LOTO Procedure in which a worker locks and tags every energy source of a machine before maintenance so it cannot restart
- Logistics 2024 Problem Japanese truck driver and delivery capacity shortage from overtime caps in April 2024, which spurred logistics automation
- Made in China 2025 Chinese industrial strategy launched in 2015 to upgrade manufacturing and cut reliance on foreign tech, including robotics
- MassRobotics Interoperability Standard Open standard letting mobile robots from different makers share position, status and routes so mixed fleets can coexist
- Mean Time Between Failures MTBF Average operating time a machine runs between breakdowns, a common measure of robot reliability
- Mean Time Between Interventions MTBI Average time a robot works alone before a person must step in to help, reset or correct it
- Mean Time to Dangerous Failure MTTFd Average time before a safety component fails in a way that stops it protecting people
- Mean Time to Repair MTTR Average time to find and fix a fault and get a machine running again
- Ministry of Economy, Trade and Industry METI Japan's ministry for industry, trade and energy and the lead ministry for robotics policy and subsidies
- Ministry of Industry and Information Technology MIIT China's ministry for industrial policy and IT and the lead agency for robotics and humanoid policy
- Moonshot Research and Development Program Japanese government program funding ambitious 2050 research goals, including autonomous AI robots that live alongside people
- Muting Safety function that briefly bypasses a light curtain or scanner while material passes, using extra sensors to tell it apart from people
- National Institute of Advanced Industrial Science and Technology AIST Japan's largest public industrial research institute, known for HRP humanoids and robot safety work
- New Energy and Industrial Technology Development Organization NEDO Japanese national agency under METI that funds and manages large robotics and industrial technology R&D programs
- Operational Stock Estimated number of industrial robots in service in a country or worldwide, the basis for robot density
- Opportunity Charging Topping up a mobile robot's battery in short bursts during idle moments rather than one long charge
- Overall Equipment Effectiveness OEE Factory score combining availability, speed and quality to show how productively a machine is used
- Payback Period Time it takes for savings from a robot to add up to its purchase and installation cost
- Performance Level PL Grade from a to e rating how reliably a machine safety function works, with e the most reliable
- Perimeter Guarding Physical fences and locked gates that keep people out of a robot cell while it runs automatically
- Picks per Hour Number of items a robot or person picks in an hour, the standard speed measure for warehouse picking
- Pilot Deployment Limited trial of robots at a customer site to test safety and payoff before a larger rollout
- Power and Force Limiting PFL Safety approach keeping force and pressure low enough on contact with a person to avoid pain or injury
- Predictive Maintenance Using sensor data to spot wear and fix parts just before they fail
- Preventive Maintenance PM Maintenance on a fixed schedule regardless of condition, such as regreasing gears or replacing batteries
- PROFIsafe Safety protocol that carries emergency stop and other safety signals over PROFINET or PROFIBUS networks
- Proof of Concept PoC Early test showing a robot can technically do a task at all, before any pilot of its economics
- Protective Separation Distance Minimum gap a robot must keep from a person under speed monitoring so it is already stopping if the person comes closer
- Protective Stop Automatic stop triggered by safety devices such as light curtains or scanners, usually easier to reset than an emergency stop
- Quasi-Static Contact Contact in which part of a person is pinched or clamped by the robot and cannot pull away, allowing much lower forces
- Reduced Speed Mode T1 Manual mode limiting tool speed to a safe walking pace so an operator can teach and test a robot up close
- Reducer Life Expected lifetime of a robot's joint gearboxes, the main wearing part that sets maintenance and replacement costs
- Residual Risk Risk left after all reasonable safety measures have been applied, which must be communicated to users
- Restricted Space Part of a robot's reach it is actually allowed to enter once limiting devices or safety rated software limits are applied
- Return on Investment ROI Money an automation project earns or saves relative to its cost, the main test for scaling a robot pilot
- Risk Assessment Structured process for finding machine hazards, judging their likelihood and severity and deciding how to reduce them
- Robot Body Manufacturer Chinese industry term for the company that designs and assembles the complete robot, between component suppliers and integrators
- Robot Cell Complete robot work area built for one job, including robot, tool, fixtures, conveyors, guarding and controls
- Robot Class 2025 ISO 10218-1 category sorting robots into Class I or Class II by mass, force and speed hazard
- Robot Density Number of industrial robots per 10,000 manufacturing workers, the standard comparison of national automation
- Robot Friendly Environment Japanese policy idea of adapting buildings, processes and equipment so robots can work in them easily
- Robot Plus Application Action Plan Chinese 2023 MIIT plan to spread robots across manufacturing and services such as logistics, healthcare and elder care
- Robot Utilization Share of available time a robot spends doing useful work rather than idle, waiting or under repair
- Robots as a Service RaaS Business model where customers rent robots by subscription or pay per hour or task instead of buying them
- Runtime How long a battery powered robot can work on one charge, which decides whether it covers a full shift
- Safe Brake Control SBC Drive safety function that reliably controls and checks a motor's holding brake
- Safe Operating Stop SOS Drive safety function that holds a motor still under power and triggers a full stop if it moves
- Safe Stop 1 SS1 Drive safety function that slows a motor under control and then safely removes torque
- Safe Stop 2 SS2 Drive safety function that slows a motor under control and then holds it still with power on under monitoring
- Safe Torque Off STO Drive safety function that cuts power that would make a motor produce force without disconnecting the drive
- Safeguarded Space Area around a robot protected by fences or sensors so people are kept out or the robot stops while it works
- Safely Limited Speed SLS Safety function that stops a robot or motor safely if its speed exceeds a set limit
- Safety Bumper Soft pressure sensitive edge on a mobile robot that stops it the moment it touches something
- Safety Category One of five ISO 13849-1 architectures, B and 1 to 4, describing how a safety circuit behaves when a part fails
- Safety Controller Safety certified computer that independently monitors a robot's positions, speeds and safety inputs and stops it if limits break
- Safety Function Machine function whose job is keeping people safe and whose failure would immediately raise the risk
- Safety Integrity Level SIL Rating from SIL 1 to SIL 4 for how reliably a safety system performs, with SIL 4 the highest
- Safety Mat Pressure sensitive floor mat that stops a machine or blocks restart when someone stands on it
- Safety PLC Programmable logic controller certified for safety tasks, using redundant processors to command safe stops
- Safety Relay Self checking relay module that monitors emergency stops, door switches and light curtains and safely cuts power
- Safety-Rated Monitored Stop SMS Collaborative method where a robot holds still under monitoring while a person is in the shared area, now called monitored standstill
- Safety-Rated Soft Axis Limiting Certified controller software that limits where a robot can move, how its tool points and how fast it goes in set zones
- Service Level Agreement SLA Contract commitment on service performance such as robot availability, fault response time and spare part delivery
- Single Point of Control Principle that while a person controls a robot by hand, no other device or computer can start or move it
- Site Acceptance Test SAT Test after installation at the customer plant confirming a robot system meets agreed performance in real production
- Specialized and Sophisticated SMEs Chinese government designation for niche leading small firms, with a top little giant tier that gets subsidies
- Speed and Separation Monitoring SSM Safety method where sensors track people's distance and the robot slows as they approach and stops before contact
- Stop Category IEC 60204-1 classification of machine stops 0, 1 and 2 by whether power is cut immediately or after controlled braking
- Stopping Distance How far a robot keeps moving after a stop command until it comes fully to rest
- System Integrator SI Company that designs, builds, programs and installs complete robot systems combining robots, tools, vision and safety
- Takt Time Pace a factory must finish each unit to meet demand, equal to available time divided by units needed
- Throughput How many units, picks or tasks a robot or system finishes in a given time
- Total Cost of Ownership TCO Full lifetime cost of a robot including purchase, integration, safety, maintenance, energy and downtime
- Transient Contact Brief bump between a robot and a person free to move away, allowing higher forces than clamping
- UL 1740 North American safety standard for robots and robotic equipment, used by test labs to certify robots for US and Canadian sale
- Unit Economics Cost and revenue tied to one robot or unit of robot work, such as cost per hour or per pick, versus human labor
- Uptime Share of scheduled time a robot is available and working rather than broken down or under repair
- Virtual Commissioning Testing a robot cell's control programs against a simulation before anything is built or installed
- Warehouse Execution System WES Software coordinating automated warehouse equipment and people in real time, between order management and machines
- Warehouse Management System WMS Software tracking warehouse inventory, locations, orders and labor that tells people and robots what to do
- World Humanoid Robot Games Multi sport humanoid robot competition first held in Beijing in August 2025 to showcase China's humanoid industry
- World Robot Conference WRC Large annual robotics conference and exhibition in Beijing where Chinese makers show robots, humanoids and components
Full entry for members
Every term has a full entry for members: the plain-words definition, the practitioner note and the typed links between terms.
ACW Robotics and Physical AI Glossary, edition 2026.11.1. The headword and one line are open to everyone.